Loading...
Searching...
No Matches
TrajectoryAlignmentHandler.cpp File Reference
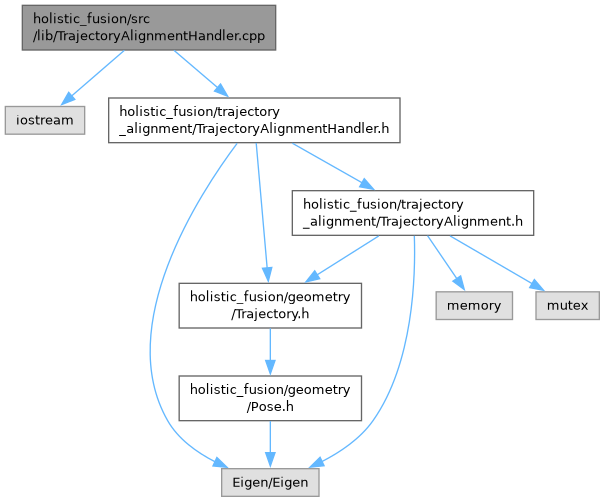
Include dependency graph for TrajectoryAlignmentHandler.cpp:
Go to the source code of this file.
Namespaces | |
| namespace | holistic_fusion |
| Absolute. | |
|
My Project 1.0
Holistic Fusion: A Generic Framework for Multimodal Sensor Fusion
|
Go to the source code of this file.
Namespaces | |
| namespace | holistic_fusion |
| Absolute. | |
 1.15.0