Loading...
Searching...
No Matches
read_ros_params.h File Reference
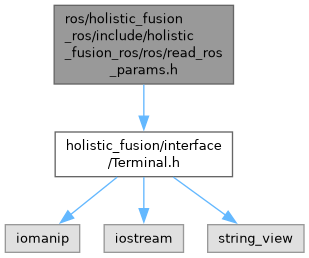
#include "holistic_fusion/interface/Terminal.h"
Include dependency graph for read_ros_params.h:
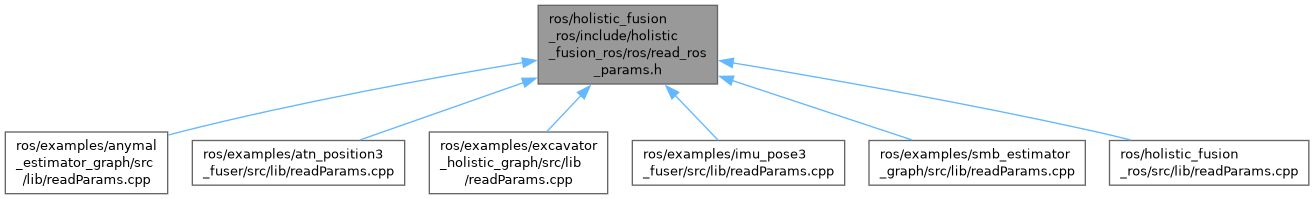
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Namespaces | |
| namespace | holistic_fusion |
| Absolute. | |
Functions | |
| template<typename T> | |
| void | holistic_fusion::printKey (const std::string &key, T value) |
| template<> | |
| void | holistic_fusion::printKey (const std::string &key, std::vector< double > vector) |
| template<typename T> | |
| T | holistic_fusion::tryGetParam (const std::string &key, const ros::NodeHandle &privateNode) |
