Loading...
Searching...
No Matches
math_utils.h File Reference
Include dependency graph for math_utils.h:
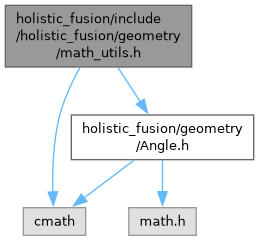
Go to the source code of this file.
Namespaces | |
| namespace | holistic_fusion |
| Absolute. | |
Functions | |
| double | holistic_fusion::rad2deg (double radians) |
| Convert the given radian angle to degrees. | |
| float | holistic_fusion::rad2deg (float radians) |
| Convert the given radian angle to degrees. | |
| double | holistic_fusion::deg2rad (double degrees) |
| Convert the given degree angle to radian. | |
| float | holistic_fusion::deg2rad (float degrees) |
| Convert the given degree angle to radian. | |
| template<typename PointT> | |
| float | holistic_fusion::calcSquaredDiff (const PointT &a, const PointT &b) |
| Calculate the squared difference of the given two points. | |
| template<typename PointT> | |
| float | holistic_fusion::calcSquaredDiff (const PointT &a, const PointT &b, const float &wb) |
| Calculate the squared difference of the given two points. | |
| template<typename PointT> | |
| float | holistic_fusion::calcPointDistance (const PointT &p) |
| Calculate the absolute distance of the point to the origin. | |
| template<typename PointT> | |
| float | holistic_fusion::calcSquaredPointDistance (const PointT &p) |
| Calculate the squared distance of the point to the origin. | |
| template<typename PointT> | |
| void | holistic_fusion::rotX (PointT &p, const Angle &ang) |
| Rotate the given point by the specified angle around the x-axis. | |
| template<typename PointT> | |
| void | holistic_fusion::rotY (PointT &p, const Angle &ang) |
| Rotate the given point by the specified angle around the y-axis. | |
| template<typename PointT> | |
| void | holistic_fusion::rotZ (PointT &p, const Angle &ang) |
| Rotate the given point by the specified angle around the z-axis. | |
| template<typename PointT> | |
| void | holistic_fusion::rotateZXY (PointT &p, const Angle &angZ, const Angle &angX, const Angle &angY) |
| Rotate the given point by the specified angles around the z-, x- respectively y-axis. | |
| template<typename PointT> | |
| void | holistic_fusion::rotateYXZ (PointT &p, const Angle &angY, const Angle &angX, const Angle &angZ) |
| Rotate the given point by the specified angles around the y-, x- respectively z-axis. | |
| void | holistic_fusion::invertHomogenousMatrix (const Eigen::Matrix4d &m_in, Eigen::Matrix4d &m_out) |
| Invert a homogenous transformation matrix. | |
