#include <DynamicTransformDictionary.h>
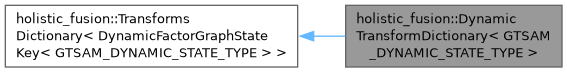

Public Member Functions | |
| DynamicTransformDictionary () | |
| ~DynamicTransformDictionary ()=default | |
| bool | removeTransform (const std::string &frame1, const std::string &frame2, DynamicFactorGraphStateKey< GTSAM_DYNAMIC_STATE_TYPE > &returnRemovedKey) override |
| bool | removeOrDeactivateTransform (const std::string &frame1, const std::string &frame2) |
| bool | getFramePairFromGtsamKey (std::pair< std::string, std::string > &framePairRef, const gtsam::Key >samKey) const |
| bool | getKeyframePositionFromGtsamKey (Eigen::Vector3d &keyframePositionRef, const gtsam::Key >samKey) const |
| const std::map< gtsam::Key, std::pair< std::string, std::string > > & | getTransformGtsamKeyToFramePairMap () const |
| template<char SYMBOL_CHAR> | |
| DynamicFactorGraphStateKey< GTSAM_DYNAMIC_STATE_TYPE > | getTransformationKey (bool &newGraphKeyAdded, const std::string &frame1, const std::string &frame2, const double timeK, const gtsam::Pose3 &approximateTransformationBeforeOptimization, const DynamicVariableType &variableType) |
| bool | getInitialGuessForFramePair (const std::string &frame1, const std::string &frame2, GTSAM_DYNAMIC_STATE_TYPE &initialGuessRef) const |
| template<char SYMBOL_CHAR> | |
| bool | addNewFramePairSafelyToDictionary (DynamicFactorGraphStateKey< GTSAM_DYNAMIC_STATE_TYPE > &returnStateKey, const std::string &frame1, const std::string &frame2, const double timeK, const gtsam::Pose3 &approximateTransformationBeforeOptimization, const DynamicVariableType &variableType) |
| void | setInitialGuessForFramePair (const std::string &frame1, const std::string &frame2, const GTSAM_DYNAMIC_STATE_TYPE &initialGuess) |
| void | removeInitialGuessForFramePair (const std::string &frame1, const std::string &frame2) |
| template<char SYMBOL_CHAR> | |
| DynamicFactorGraphStateKey< GTSAM_DYNAMIC_STATE_TYPE > | addNewFactorGraphStateKey (const std::string &frame1, const std::string &frame2, const double timeK, const gtsam::Pose3 &approximateTransformationBeforeOptimization, const DynamicVariableType &variableType) |
| std::mutex & | mutex () |
| Public Member Functions inherited from holistic_fusion::TransformsDictionary< DynamicFactorGraphStateKey< GTSAM_DYNAMIC_STATE_TYPE > > | |
| TransformsDictionary (DynamicFactorGraphStateKey< GTSAM_DYNAMIC_STATE_TYPE > identityObject) | |
| bool | isFramePairInDictionary (const std::string &frame1, const std::string &frame2) |
| size_t | getNumberStoredTransformationPairs () |
| DynamicFactorGraphStateKey< GTSAM_DYNAMIC_STATE_TYPE > & | lv_T_frame1_frame2 (const std::string &frame1, const std::string &frame2) |
| const DynamicFactorGraphStateKey< GTSAM_DYNAMIC_STATE_TYPE > & | rv_T_frame1_frame2 (const std::string &frame1, const std::string &frame2) const |
| std::map< std::pair< std::string, std::string >, DynamicFactorGraphStateKey< GTSAM_DYNAMIC_STATE_TYPE > > & | getTransformsMap () |
| void | set_T_frame1_frame2_andInverse (const std::string &frame1, const std::string &frame2, const DynamicFactorGraphStateKey< GTSAM_DYNAMIC_STATE_TYPE > &T_frame1_frame2) |
| void | set_T_frame1_frame2 (const std::string &frame1, const std::string &frame2, const DynamicFactorGraphStateKey< GTSAM_DYNAMIC_STATE_TYPE > T_frame1_frame2) |
Private Attributes | |
| std::map< gtsam::Key, std::pair< std::string, std::string > > | transformGtsamKeyToFramePairMap_ |
| std::map< gtsam::Key, Eigen::Vector3d > | transformGtsamKeyToKeyframePositionMap_ |
| std::map< std::pair< std::string, std::string >, GTSAM_DYNAMIC_STATE_TYPE > | transformGtsamKeyToInitialGuessMap_ |
| std::mutex | internalDictionaryModifierMutex_ |
| std::mutex | externalModifierMutex_ |
| std::array< unsigned long, sizeof(ADMISSIBLE_DYNAMIC_SYMBOL_CHARS)> | numStoredTransformsPerSymbol_ |
Detailed Description
class holistic_fusion::DynamicTransformDictionary< GTSAM_DYNAMIC_STATE_TYPE >
Definition at line 33 of file DynamicTransformDictionary.h.
Constructor & Destructor Documentation
◆ DynamicTransformDictionary()
|
inline |
Definition at line 36 of file DynamicTransformDictionary.h.
◆ ~DynamicTransformDictionary()
|
default |
Member Function Documentation
◆ addNewFactorGraphStateKey()
|
inline |
Definition at line 218 of file DynamicTransformDictionary.h.
◆ addNewFramePairSafelyToDictionary()
|
inline |
Definition at line 174 of file DynamicTransformDictionary.h.
◆ getFramePairFromGtsamKey()
|
inline |
Definition at line 120 of file DynamicTransformDictionary.h.
◆ getInitialGuessForFramePair()
|
inline |
Definition at line 163 of file DynamicTransformDictionary.h.
◆ getKeyframePositionFromGtsamKey()
|
inline |
Definition at line 132 of file DynamicTransformDictionary.h.
◆ getTransformationKey()
|
inline |
Definition at line 150 of file DynamicTransformDictionary.h.
◆ getTransformGtsamKeyToFramePairMap()
|
inlinenodiscard |
Definition at line 144 of file DynamicTransformDictionary.h.
◆ mutex()
|
inline |
Definition at line 253 of file DynamicTransformDictionary.h.
◆ removeInitialGuessForFramePair()
|
inline |
Definition at line 211 of file DynamicTransformDictionary.h.
◆ removeOrDeactivateTransform()
|
inline |
Definition at line 68 of file DynamicTransformDictionary.h.
◆ removeTransform()
|
inlineoverridevirtual |
Reimplemented from holistic_fusion::TransformsDictionary< DynamicFactorGraphStateKey< GTSAM_DYNAMIC_STATE_TYPE > >.
Definition at line 45 of file DynamicTransformDictionary.h.
◆ setInitialGuessForFramePair()
|
inline |
Definition at line 206 of file DynamicTransformDictionary.h.
Member Data Documentation
◆ externalModifierMutex_
|
private |
Definition at line 265 of file DynamicTransformDictionary.h.
◆ internalDictionaryModifierMutex_
|
private |
Definition at line 264 of file DynamicTransformDictionary.h.
◆ numStoredTransformsPerSymbol_
|
private |
Definition at line 268 of file DynamicTransformDictionary.h.
◆ transformGtsamKeyToFramePairMap_
|
private |
Definition at line 257 of file DynamicTransformDictionary.h.
◆ transformGtsamKeyToInitialGuessMap_
|
private |
Definition at line 261 of file DynamicTransformDictionary.h.
◆ transformGtsamKeyToKeyframePositionMap_
|
private |
Definition at line 259 of file DynamicTransformDictionary.h.
The documentation for this class was generated from the following file:
- holistic_fusion/include/holistic_fusion/core/DynamicTransformDictionary.h
