Loading...
Searching...
No Matches
DynamicFactorGraphStateKey.h File Reference
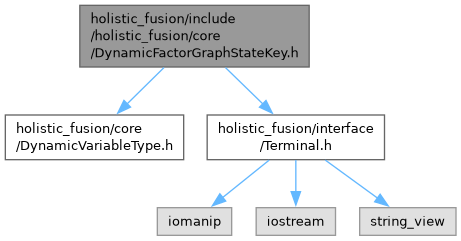
#include "holistic_fusion/core/DynamicVariableType.h"#include "holistic_fusion/interface/Terminal.h"
Include dependency graph for DynamicFactorGraphStateKey.h:
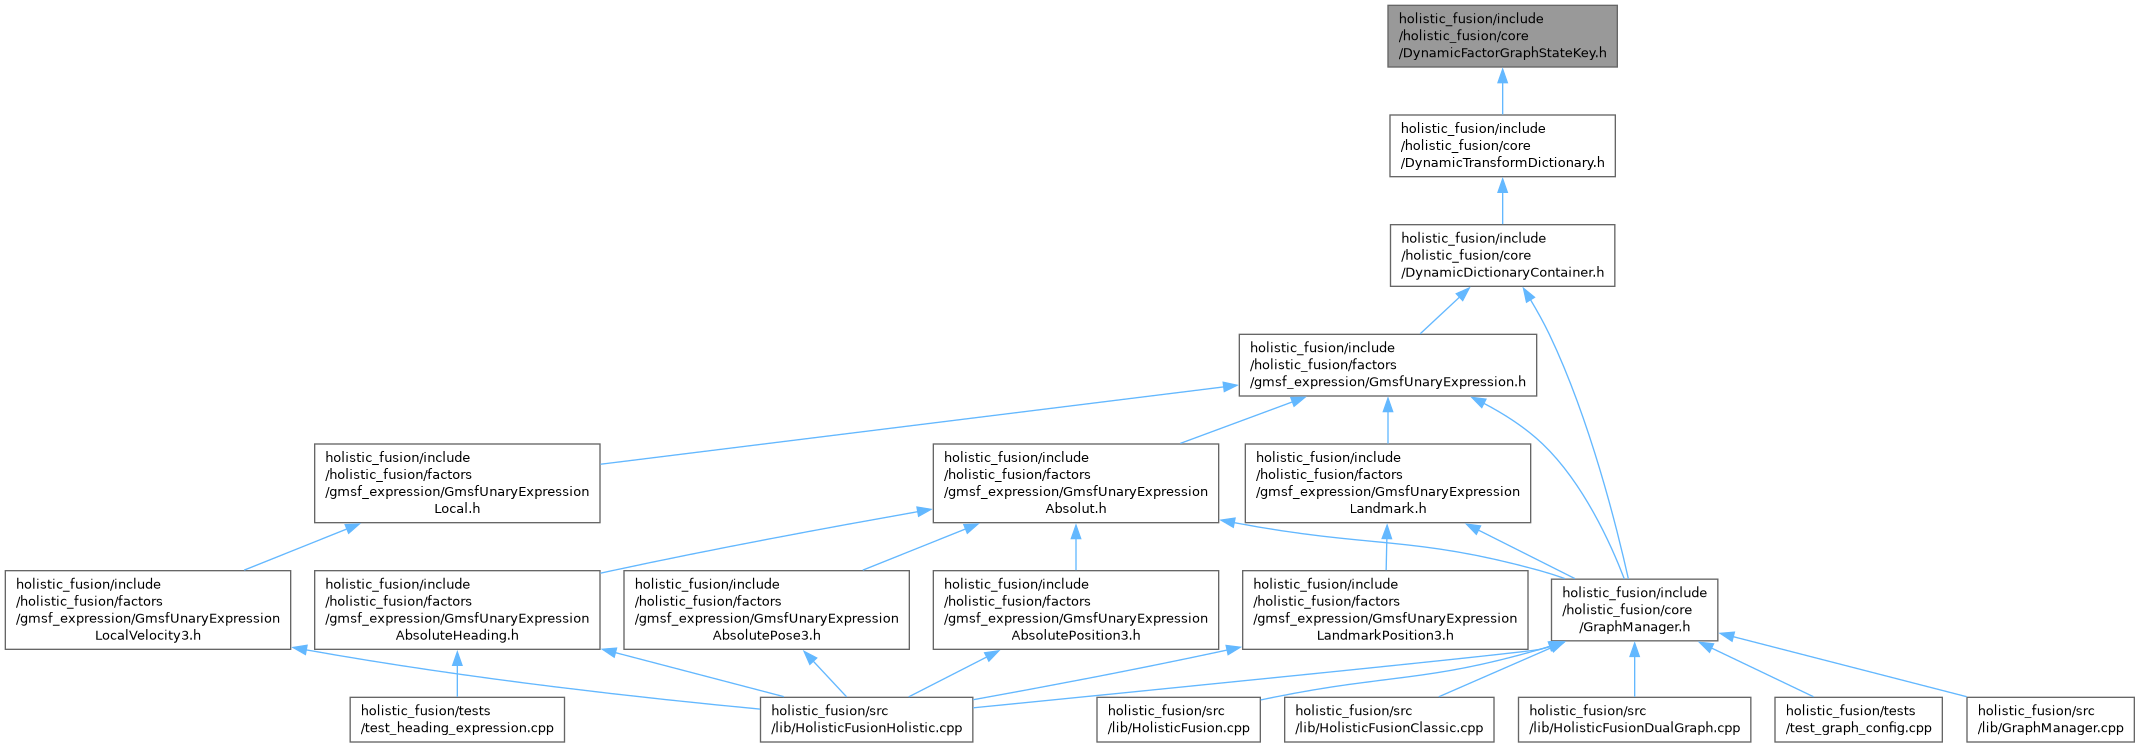
This graph shows which files directly or indirectly include this file:
Go to the source code of this file.
Classes | |
| class | holistic_fusion::DynamicFactorGraphStateKey< GTSAM_TRANSFORM_TYPE > |
Namespaces | |
| namespace | holistic_fusion |
| Absolute. | |
Macros | |
| #define | REGULAR_COUT std::cout << YELLOW_START << "GMSF-FactorGraphStateKey" << COLOR_END |
Macro Definition Documentation
◆ REGULAR_COUT
| #define REGULAR_COUT std::cout << YELLOW_START << "GMSF-FactorGraphStateKey" << COLOR_END |
Definition at line 16 of file DynamicFactorGraphStateKey.h.
