#include <GmsfUnaryExpressionAbsoluteHeading.h>
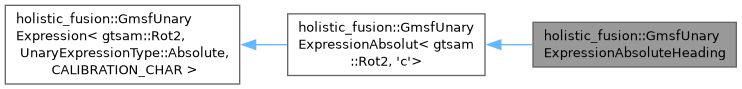
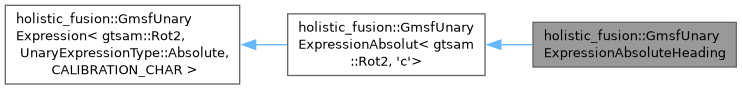
Public Member Functions | |
| GmsfUnaryExpressionAbsoluteHeading (const std::shared_ptr< UnaryMeasurementXDAbsolute< Eigen::Matrix3d, 1 > > &headingUnaryMeasurementPtr, const std::string &imuFrameName, const Eigen::Isometry3d &T_I_sensorFrame, const double createReferenceAlignmentKeyframeEveryNSeconds) | |
| ~GmsfUnaryExpressionAbsoluteHeading ()=default | |
| const gtsam::Vector | getNoiseDensity () const override |
| const gtsam::Rot2 | getGtsamMeasurementValue () const override |
| Public Member Functions inherited from holistic_fusion::GmsfUnaryExpressionAbsolut< gtsam::Rot2, 'c'> | |
| GmsfUnaryExpressionAbsolut (const std::shared_ptr< UnaryMeasurementAbsolute > &gmsfUnaryAbsoluteMeasurementPtr, const std::string &imuFrameName, const Eigen::Isometry3d &T_I_sensorFrame, const double createReferenceAlignmentKeyframeEveryNSeconds) | |
| ~GmsfUnaryExpressionAbsolut ()=default | |
| Public Member Functions inherited from holistic_fusion::GmsfUnaryExpression< gtsam::Rot2, UnaryExpressionType::Absolute, CALIBRATION_CHAR > | |
| GmsfUnaryExpression (const std::shared_ptr< UnaryMeasurement > &gmsfBaseUnaryMeasurementPtr, const std::string &imuFrameName, const Eigen::Isometry3d &T_I_sensorFrame) | |
| ~GmsfUnaryExpression ()=default | |
| gtsam::Expression< gtsam::Rot2 > | createAndReturnExpression (const gtsam::Key &closestGeneralKey, DynamicDictionaryContainer >samDynamicExpressionKeys, const gtsam::NavState &W_imuPropagatedState, const bool optimizeReferenceFramePosesWrtWorldFlag, const bool centerMeasurementsAtKeyframePositionBeforeAlignmentFlag, const bool optimizeExtrinsicSensorToSensorCorrectedOffsetFlag) |
| virtual const std::shared_ptr< UnaryMeasurement > & | getGmsfBaseUnaryMeasurementPtr () |
| double | getTimestamp () const |
| const gtsam::Values & | getNewOnlineGraphStateValues () const |
| const gtsam::Values & | getNewOfflineGraphStateValues () const |
| const std::vector< gtsam::PriorFactor< gtsam::Pose3 > > & | getNewOnlinePosePriorFactors () const |
| const std::vector< gtsam::PriorFactor< gtsam::Rot2 > > & | getNewOnlineDynamicPriorFactors () const |
| const std::vector< gtsam::BetweenFactor< gtsam::Pose3 > > & | getNewOnlineAndOfflinePoseBetweenFactors () const |
| const Eigen::Isometry3d & | getT_I_sensorFrameInit () const |
Protected Member Functions | |
| void | generateImuStateInWorldFrameAtKey (const gtsam::Key &closestGeneralKey) final |
| bool | measuresPosition () const final |
| gtsam::Pose3 | computeT_W_fixedFrame_initial (const gtsam::NavState &) final |
| const Eigen::Vector3d | getMeasurementPosition () final |
| void | setMeasurementPosition (const Eigen::Vector3d &) final |
| void | transformStateToReferenceFrameMeasurement (const gtsam::Pose3_ &exp_T_W_fixedFrame) override |
| void | transformImuStateToSensorFrameState () final |
| void | transformSensorFrameStateToSensorFrameCorrectedState (DynamicDictionaryContainer &) final |
| void | applyExtrinsicCalibrationCorrection (const gtsam::Expression< gtsam::Rot2 > &) final |
| gtsam::Pose3 | convertToPose3 (const gtsam::Rot2 &) final |
| gtsam::Rot2 | convertFromPose3 (const gtsam::Pose3 &) final |
| const gtsam::Expression< gtsam::Rot2 > | getGtsamExpression () const override |
| Protected Member Functions inherited from holistic_fusion::GmsfUnaryExpressionAbsolut< gtsam::Rot2, 'c'> | |
| void | transformImuStateFromWorldToReferenceFrame (DynamicDictionaryContainer >samDynamicExpressionKeys, const gtsam::NavState &W_currentPropagatedState, const bool centerMeasurementsAtKeyframePositionBeforeAlignmentFlag) final |
| void | transformLandmarkInWorldToImuFrame (DynamicDictionaryContainer >samDynamicExpressionKeys, const gtsam::NavState &W_currentPropagatedState) final |
Private Attributes | |
| std::shared_ptr< UnaryMeasurementXDAbsolute< Eigen::Matrix3d, 1 > > | headingUnaryMeasurementPtr_ |
| gtsam::Expression< gtsam::Rot3 > | exp_R_W_S_ |
| gtsam::Expression< gtsam::Rot3 > | exp_R_W_fixedFrame_ |
Additional Inherited Members | |
| Public Types inherited from holistic_fusion::GmsfUnaryExpression< gtsam::Rot2, UnaryExpressionType::Absolute, CALIBRATION_CHAR > | |
| using | template_type |
| Protected Attributes inherited from holistic_fusion::GmsfUnaryExpression< gtsam::Rot2, UnaryExpressionType::Absolute, CALIBRATION_CHAR > | |
| const std::shared_ptr< UnaryMeasurement > | gmsfBaseUnaryMeasurementPtr_ |
| const std::string | imuFrame_ |
| Eigen::Isometry3d | T_I_sensorFrameInit_ |
| gtsam::Values | newOnlineStateValues_ |
| gtsam::Values | newOfflineStateValues_ |
| std::vector< gtsam::PriorFactor< gtsam::Pose3 > > | newOnlinePosePriorFactors_ |
| std::vector< gtsam::PriorFactor< gtsam::Rot2 > > | newOnlineDynamicPriorFactors_ |
| std::vector< gtsam::BetweenFactor< gtsam::Pose3 > > | newOnlineAndOfflinePoseBetweenFactors_ |
Detailed Description
Expression that constrains the heading of a sensor frame S: the rotation about the z-axis of the world between the estimated and the measured orientation of S. Rotations about the horizontal axes of the world leave it unchanged to first order, so it does not compete with gravity over roll and pitch. For equal roll and pitch, it equals the Euler yaw difference. If the fixed frame M of the measurement is not the world frame and fixed frames are optimized, the measurement goes through the alignment R_W_M. A heading measurement has no position, so it reuses the current alignment keyframe of M and never creates one.
Definition at line 53 of file GmsfUnaryExpressionAbsoluteHeading.h.
Constructor & Destructor Documentation
◆ GmsfUnaryExpressionAbsoluteHeading()
|
inline |
Definition at line 56 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ ~GmsfUnaryExpressionAbsoluteHeading()
|
default |
Member Function Documentation
◆ applyExtrinsicCalibrationCorrection()
|
inlinefinalprotectedvirtual |
Implements holistic_fusion::GmsfUnaryExpression< gtsam::Rot2, UnaryExpressionType::Absolute, CALIBRATION_CHAR >.
Definition at line 105 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ computeT_W_fixedFrame_initial()
|
inlinefinalprotectedvirtual |
Implements holistic_fusion::GmsfUnaryExpressionAbsolut< gtsam::Rot2, 'c'>.
Definition at line 84 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ convertFromPose3()
|
inlinefinalprotectedvirtual |
Implements holistic_fusion::GmsfUnaryExpression< gtsam::Rot2, UnaryExpressionType::Absolute, CALIBRATION_CHAR >.
Definition at line 114 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ convertToPose3()
|
inlinefinalprotectedvirtual |
Implements holistic_fusion::GmsfUnaryExpression< gtsam::Rot2, UnaryExpressionType::Absolute, CALIBRATION_CHAR >.
Definition at line 110 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ generateImuStateInWorldFrameAtKey()
|
inlinefinalprotectedvirtual |
Implements holistic_fusion::GmsfUnaryExpression< gtsam::Rot2, UnaryExpressionType::Absolute, CALIBRATION_CHAR >.
Definition at line 76 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ getGtsamExpression()
|
inlinenodiscardoverrideprotectedvirtual |
Implements holistic_fusion::GmsfUnaryExpression< gtsam::Rot2, UnaryExpressionType::Absolute, CALIBRATION_CHAR >.
Definition at line 119 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ getGtsamMeasurementValue()
|
inlinenodiscardoverridevirtual |
Implements holistic_fusion::GmsfUnaryExpression< gtsam::Rot2, UnaryExpressionType::Absolute, CALIBRATION_CHAR >.
Definition at line 72 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ getMeasurementPosition()
|
inlinefinalprotectedvirtual |
Implements holistic_fusion::GmsfUnaryExpressionAbsolut< gtsam::Rot2, 'c'>.
Definition at line 86 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ getNoiseDensity()
|
inlinenodiscardoverridevirtual |
Implements holistic_fusion::GmsfUnaryExpression< gtsam::Rot2, UnaryExpressionType::Absolute, CALIBRATION_CHAR >.
Definition at line 69 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ measuresPosition()
|
inlinefinalprotectedvirtual |
Implements holistic_fusion::GmsfUnaryExpressionAbsolut< gtsam::Rot2, 'c'>.
Definition at line 81 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ setMeasurementPosition()
|
inlinefinalprotectedvirtual |
Implements holistic_fusion::GmsfUnaryExpressionAbsolut< gtsam::Rot2, 'c'>.
Definition at line 88 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ transformImuStateToSensorFrameState()
|
inlinefinalprotectedvirtual |
Implements holistic_fusion::GmsfUnaryExpression< gtsam::Rot2, UnaryExpressionType::Absolute, CALIBRATION_CHAR >.
Definition at line 98 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ transformSensorFrameStateToSensorFrameCorrectedState()
|
inlinefinalprotectedvirtual |
Reimplemented from holistic_fusion::GmsfUnaryExpression< gtsam::Rot2, UnaryExpressionType::Absolute, CALIBRATION_CHAR >.
Definition at line 101 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ transformStateToReferenceFrameMeasurement()
|
inlineoverrideprotectedvirtual |
Implements holistic_fusion::GmsfUnaryExpressionAbsolut< gtsam::Rot2, 'c'>.
Definition at line 93 of file GmsfUnaryExpressionAbsoluteHeading.h.
Member Data Documentation
◆ exp_R_W_fixedFrame_
|
private |
Definition at line 129 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ exp_R_W_S_
|
private |
Definition at line 128 of file GmsfUnaryExpressionAbsoluteHeading.h.
◆ headingUnaryMeasurementPtr_
|
private |
Definition at line 125 of file GmsfUnaryExpressionAbsoluteHeading.h.
The documentation for this class was generated from the following file:
- holistic_fusion/include/holistic_fusion/factors/gmsf_expression/GmsfUnaryExpressionAbsoluteHeading.h
