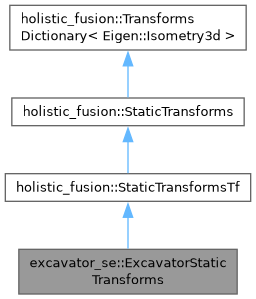
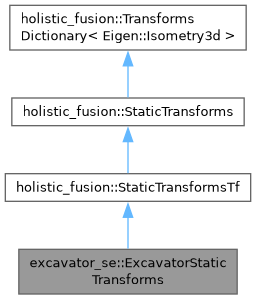
#include <ExcavatorStaticTransforms.h>
|
| | ExcavatorStaticTransforms (const std::shared_ptr< ros::NodeHandle > privateNodePtr) |
| void | setLioOdometryFrame (const std::string &s) |
| void | setLeftGnssFrame (const std::string &s) |
| void | setRightGnssFrame (const std::string &s) |
| void | setCabinFrame (const std::string &s) |
| const std::string & | getLioOdometryFrame () |
| const std::string & | getLeftGnssFrame () |
| const std::string & | getRightGnssFrame () |
| const std::string & | getCabinFrame () |
| | StaticTransformsTf ()=default |
| | StaticTransforms () |
| void | setImuFrame (const std::string &s) |
| void | setWorldFrame (const std::string &s) |
| void | setOdomFrame (const std::string &s) |
| void | setBaseLinkFrame (const std::string &s) |
| void | setInitializationFrame (const std::string &s) |
| const std::string & | getImuFrame () |
| const std::string & | getWorldFrame () |
| const std::string & | getOdomFrame () |
| const std::string & | getBaseLinkFrame () |
| const std::string & | getInitializationFrame () |
| | TransformsDictionary (Eigen::Isometry3d identityObject) |
| bool | isFramePairInDictionary (const std::string &frame1, const std::string &frame2) |
| virtual bool | removeTransform (const std::string &frame1, const std::string &frame2, Eigen::Isometry3d &removedTransform) |
| size_t | getNumberStoredTransformationPairs () |
| Eigen::Isometry3d & | lv_T_frame1_frame2 (const std::string &frame1, const std::string &frame2) |
| const Eigen::Isometry3d & | rv_T_frame1_frame2 (const std::string &frame1, const std::string &frame2) const |
| std::map< std::pair< std::string, std::string >, Eigen::Isometry3d > & | getTransformsMap () |
| void | set_T_frame1_frame2_andInverse (const std::string &frame1, const std::string &frame2, const Eigen::Isometry3d &T_frame1_frame2) |
| void | set_T_frame1_frame2 (const std::string &frame1, const std::string &frame2, const Eigen::Isometry3d T_frame1_frame2) |
Definition at line 15 of file ExcavatorStaticTransforms.h.
◆ ExcavatorStaticTransforms()
| excavator_se::ExcavatorStaticTransforms::ExcavatorStaticTransforms |
( |
const std::shared_ptr< ros::NodeHandle > | privateNodePtr | ) |
|
◆ findTransformations()
| bool excavator_se::ExcavatorStaticTransforms::findTransformations |
( |
| ) |
|
|
overrideprotectedvirtual |
◆ getCabinFrame()
| const std::string & excavator_se::ExcavatorStaticTransforms::getCabinFrame |
( |
| ) |
|
|
inline |
◆ getLeftGnssFrame()
| const std::string & excavator_se::ExcavatorStaticTransforms::getLeftGnssFrame |
( |
| ) |
|
|
inline |
◆ getLioOdometryFrame()
| const std::string & excavator_se::ExcavatorStaticTransforms::getLioOdometryFrame |
( |
| ) |
|
|
inline |
◆ getRightGnssFrame()
| const std::string & excavator_se::ExcavatorStaticTransforms::getRightGnssFrame |
( |
| ) |
|
|
inline |
◆ setCabinFrame()
| void excavator_se::ExcavatorStaticTransforms::setCabinFrame |
( |
const std::string & | s | ) |
|
|
inline |
◆ setLeftGnssFrame()
| void excavator_se::ExcavatorStaticTransforms::setLeftGnssFrame |
( |
const std::string & | s | ) |
|
|
inline |
◆ setLioOdometryFrame()
| void excavator_se::ExcavatorStaticTransforms::setLioOdometryFrame |
( |
const std::string & | s | ) |
|
|
inline |
◆ setRightGnssFrame()
| void excavator_se::ExcavatorStaticTransforms::setRightGnssFrame |
( |
const std::string & | s | ) |
|
|
inline |
◆ cabinFrame_
| std::string excavator_se::ExcavatorStaticTransforms::cabinFrame_ |
|
private |
◆ leftGnssFrame_
| std::string excavator_se::ExcavatorStaticTransforms::leftGnssFrame_ |
|
private |
◆ lidarFrame_
| std::string excavator_se::ExcavatorStaticTransforms::lidarFrame_ |
|
private |
◆ rightGnssFrame_
| std::string excavator_se::ExcavatorStaticTransforms::rightGnssFrame_ |
|
private |
The documentation for this class was generated from the following files: