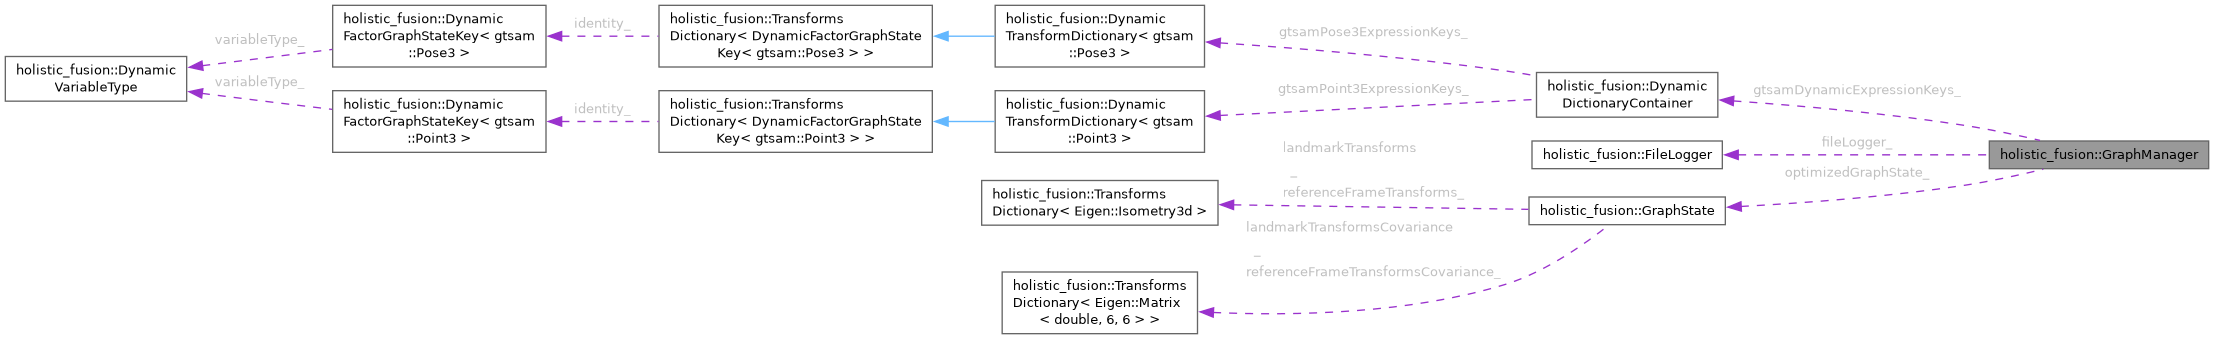
GraphManager class. More...
#include <GraphManager.h>
Public Types | |
| typedef gtsam::Key(* | F) (std::uint64_t) |
Public Member Functions | |
| GraphManager (std::shared_ptr< GraphConfig > graphConfigPtr, std::string imuFrame, std::string worldFrame) | |
| ~GraphManager () | |
| bool | initImuIntegrators (double gravityValue) |
| bool | initPoseVelocityBiasGraph (double timeStamp, const gtsam::Pose3 &T_W_I0, const gtsam::Pose3 &T_O_I0, const gtsam::Vector3 &imuAngularVelocity) |
| void | addImuFactorAndGetState (SafeIntegratedNavState &returnPreIntegratedNavState, std::shared_ptr< SafeNavStateWithCovarianceAndBias > &newOptimizedNavStatePtr, const std::shared_ptr< ImuBuffer > &imuBufferPtr, double imuTimeK, bool createNewStateFlag) |
| bool | getUnaryFactorGeneralKey (gtsam::Key &returnedKey, double &returnedGraphTime, const UnaryMeasurement &unaryMeasurement) |
| bool | hasReferenceFrameKeyframe (const std::string &worldFrame, const std::string &fixedFrame) |
| template<class MEASUREMENT_TYPE, int NOISE_DIM, class FACTOR_TYPE, F SYMBOL_SHORTHAND, class... FACTOR_ARGS> | |
| void | addUnaryClassicFactor (const MEASUREMENT_TYPE &unaryMeasurement, const Eigen::Matrix< double, NOISE_DIM, 1 > &unaryNoiseDensity, double measurementTime, const FACTOR_ARGS &... factorArgs) |
| template<class GMSF_EXPRESSION_TYPE> | |
| void | addUnaryHolisticFactor (const std::shared_ptr< GMSF_EXPRESSION_TYPE > gmsfUnaryExpressionPtr, const bool addToOnlineSmootherFlag=true) |
| gtsam::Key | addPoseBetweenFactor (const gtsam::Pose3 &deltaPose, const Eigen::Matrix< double, 6, 1 > &poseBetweenNoiseDensity, double lidarTimeKm1, double lidarTimeK, double rate, const RobustNormEnum &robustNormEnum, const double robustNormConstant) |
| bool | setInitialWorldFrameToFixedFrameTransform (const Eigen::Isometry3d &T_W_F, const std::string &fixedFrame) |
| void | updateGraph () |
| bool | optimizeSlowBatchSmoother (int maxIterations, const std::string &savePath, const bool saveCovarianceFlag) |
| std::optional< BatchOptimizationResult > | optimizeSlowBatchSmoother (int maxIterations, const bool computePoseCovarianceFlag) |
| bool | logRealTimeNavStates (const std::string &savePath, const std::string &timeString) |
| bool | logRealTimeReferenceFrameStates (const std::string &savePath, const std::string &timeString) |
| bool | logLatencyAndUpdateDuration (const std::string &savePath, const std::string &timeString) |
| void | saveOptimizedValuesToFile (const gtsam::Values &optimizedValues, const std::map< gtsam::Key, double > &keyTimestampMap, const std::string &savePath, const bool saveCovarianceFlag) |
| gtsam::NavState | calculateStateAtGeneralKey (bool &computeSuccessfulFlag, const gtsam::Key &generalKey) |
| Eigen::Vector3d & | getInitAccBiasReference () |
| Getters. | |
| Eigen::Vector3d & | getInitGyrBiasReference () |
| const GraphState & | getOptimizedGraphState () |
| const gtsam::Key | getPropagatedStateKey () |
Static Public Member Functions | |
| static void | saveOptimizedGraphToG2o (const OptimizerBase &optimizedGraph, const gtsam::Values &optimizedValues, const std::string &saveFileName) |
Static Protected Member Functions | |
| static gtsam::NavState | calculateNavStateAtGeneralKey (bool &computeSuccessfulFlag, std::shared_ptr< holistic_fusion::OptimizerBase > graphPtr, const gtsam::Key &generalKey, const char *callingFunctionName) |
| static Eigen::Matrix< double, 6, 6 > | calculatePoseCovarianceAtKeyInWorldFrame (std::shared_ptr< holistic_fusion::OptimizerBase > graphPtr, const gtsam::Key &graphKey, const char *callingFunctionName, std::optional< const gtsam::NavState > optionalNavState=std::nullopt) |
Private Member Functions | |
| bool | runSlowBatchSmootherOptimization_ (int maxIterations) |
| BatchOptimizationResult | extractBatchOptimizationResult_ (const bool computePoseCovarianceFlag) |
| template<class CHILDPTR> | |
| bool | addFactorToRtAndBatchGraph_ (const gtsam::NoiseModelFactor *noiseModelFactorPtr, const bool addToOnlineSmootherFlag=true) |
| template<class CHILDPTR> | |
| bool | addFactorToRtAndBatchGraph_ (const gtsam::NoiseModelFactor *noiseModelFactorPtr, double measurementTimestamp, const std::string &measurementName, const bool addToOnlineSmootherFlag=true) |
| template<class CHILDPTR> | |
| bool | addFactorSafelyToRtAndBatchGraph_ (const gtsam::NoiseModelFactor *noiseModelFactorPtr, double measurementTimestamp) |
| void | updateImuIntegrators_ (const TimeToImuMap &imuMeas) |
| Update IMU integrators. | |
| bool | addFactorsToRtSmootherAndOptimize (const gtsam::NonlinearFactorGraph &newRtGraphFactors, const gtsam::Values &newRtGraphValues, const std::map< gtsam::Key, double > &newRtGraphKeysTimestampsMap, const std::shared_ptr< GraphConfig > &graphConfigPtr, const int additionalIterations) |
| bool | addFactorsToBatchSmootherAndOptimize (const gtsam::NonlinearFactorGraph &newBatchGraphFactors, const gtsam::Values &newBatchGraphValues, const std::map< gtsam::Key, double > &newBatchGraphKeysTimestampsMap, const std::shared_ptr< GraphConfig > &graphConfigPtr) |
| bool | findGraphKeys_ (gtsam::Key &closestKeyKm1, gtsam::Key &closestKeyK, double &keyTimeStampDistance, double maxTimestampDistance, double timeKm1, double timeK, const std::string &name) |
| Find graph keys for timestamps. | |
| const uint64_t | newPropagatedStateKey_ () |
| Generate new key. | |
| void | writeKeyToKeyTimeStampMap_ (const gtsam::Key &key, double measurementTime, std::shared_ptr< std::map< gtsam::Key, double > > keyTimestampMapPtr) |
| Associate timestamp to each 'value key', e.g. for graph key 0, value keys (x0,v0,b0) need to be associated. | |
| void | writeValueKeysToKeyTimeStampMap_ (const gtsam::Values &values, double measurementTime, std::shared_ptr< std::map< gtsam::Key, double > > keyTimestampMapPtr) |
Private Attributes | |
| std::shared_ptr< TimeGraphKeyBuffer > | timeToKeyBufferPtr_ |
| std::string | imuFrame_ |
| std::string | worldFrame_ |
| DynamicDictionaryContainer | gtsamDynamicExpressionKeys_ |
| FileLogger | fileLogger_ |
| std::shared_ptr< gtsam::PreintegratedCombinedMeasurements::Params > | imuParamsPtr_ |
| std::shared_ptr< gtsam::imuBias::ConstantBias > | imuBiasPriorPtr_ |
| holistic_fusion::GraphState | optimizedGraphState_ |
| gtsam::NavState | W_imuPropagatedState_ = gtsam::NavState(gtsam::Pose3(), gtsam::Vector3(0, 0, 0)) |
| Propagated state (at IMU frequency). | |
| gtsam::NavState | O_imuPropagatedState_ = gtsam::NavState(gtsam::Pose3(), gtsam::Vector3(0, 0, 0)) |
| Eigen::Isometry3d | T_W_O_ = Eigen::Isometry3d::Identity() |
| gtsam::Key | propagatedStateKey_ = 0 |
| double | propagatedImuSampleTime_ = 0.0 |
| double | latestGraphStateKeyTime_ = 0.0 |
| double | lastOptimizedStateTime_ = 0.0 |
| gtsam::Vector3 | latestGraphStateKeyAngularVelocity_ = gtsam::Vector3(0, 0, 0) |
| std::shared_ptr< OptimizerBase > | rtOptimizerPtr_ |
| std::shared_ptr< OptimizerBase > | batchOptimizerPtr_ |
| std::shared_ptr< gtsam::NonlinearFactorGraph > | rtFactorGraphBufferPtr_ |
| Data buffer. | |
| std::shared_ptr< gtsam::NonlinearFactorGraph > | batchFactorGraphBufferPtr_ |
| std::shared_ptr< gtsam::Values > | rtGraphValuesBufferPtr_ |
| std::shared_ptr< gtsam::Values > | batchGraphValuesBufferPtr_ |
| std::shared_ptr< std::map< gtsam::Key, double > > | rtGraphKeysTimestampsMapBufferPtr_ |
| std::shared_ptr< std::map< gtsam::Key, double > > | batchGraphKeysTimestampsMapBufferPtr_ |
| std::shared_ptr< gtsam::PreintegratedCombinedMeasurements > | imuStepPreintegratorPtr_ |
| Step Preintegrator. | |
| std::shared_ptr< gtsam::PreintegratedCombinedMeasurements > | imuBufferPreintegratorPtr_ |
| Buffer Preintegrator. | |
| gtsam::Vector6 | lastImuVector_ |
| IMU Buffer. | |
| std::shared_ptr< holistic_fusion::GraphConfig > | graphConfigPtr_ = nullptr |
| Config. | |
| std::map< double, gtsam::Pose3 > | realTimeWorldPoseContainer_ = {} |
| std::map< double, gtsam::Pose3 > | realTimeOdomPoseContainer_ = {} |
| std::map< double, TransformsDictionary< Eigen::Isometry3d > > | realTimeReferenceFrameContainer_ = {} |
| std::set< std::pair< std::string, std::string > > | realTimeReferenceFrameNamePairs_ = {} |
| std::chrono::time_point< std::chrono::high_resolution_clock > | latencyStartTime_ |
| std::chrono::time_point< std::chrono::high_resolution_clock > | latencyEndTime_ |
| std::map< double, double > | latencyContainer_ = {} |
| std::chrono::time_point< std::chrono::high_resolution_clock > | updateDurationStartTime_ |
| std::chrono::time_point< std::chrono::high_resolution_clock > | updateDurationEndTime_ |
| std::map< double, double > | updateDurationContainer_ = {} |
| std::mutex | operateOnGraphDataMutex_ |
| Mutex. | |
| std::mutex | optimizationRunningMutex_ |
Detailed Description
GraphManager class.
The GraphManager class is the central class of the HolisticFusion library. It manages the graph, the optimization, and the real-time and batch optimization. It also provides the interface to add measurements to the graph and to retrieve the optimized states.
Definition at line 51 of file GraphManager.h.
Member Typedef Documentation
◆ F
| typedef gtsam::Key(* holistic_fusion::GraphManager::F) (std::uint64_t) |
Definition at line 83 of file GraphManager.h.
Constructor & Destructor Documentation
◆ GraphManager()
| holistic_fusion::GraphManager::GraphManager | ( | std::shared_ptr< GraphConfig > | graphConfigPtr, |
| std::string | imuFrame, | ||
| std::string | worldFrame ) |
Definition at line 61 of file GraphManager.cpp.
◆ ~GraphManager()
|
inline |
Definition at line 54 of file GraphManager.h.
Member Function Documentation
◆ addFactorSafelyToRtAndBatchGraph_()
|
private |
◆ addFactorsToBatchSmootherAndOptimize()
|
private |
Definition at line 1362 of file GraphManager.cpp.
◆ addFactorsToRtSmootherAndOptimize()
|
private |
Definition at line 1332 of file GraphManager.cpp.
◆ addFactorToRtAndBatchGraph_() [1/2]
|
private |
◆ addFactorToRtAndBatchGraph_() [2/2]
|
private |
◆ addImuFactorAndGetState()
| void holistic_fusion::GraphManager::addImuFactorAndGetState | ( | SafeIntegratedNavState & | returnPreIntegratedNavState, |
| std::shared_ptr< SafeNavStateWithCovarianceAndBias > & | newOptimizedNavStatePtr, | ||
| const std::shared_ptr< ImuBuffer > & | imuBufferPtr, | ||
| double | imuTimeK, | ||
| bool | createNewStateFlag ) |
Definition at line 229 of file GraphManager.cpp.
◆ addPoseBetweenFactor()
| gtsam::Key holistic_fusion::GraphManager::addPoseBetweenFactor | ( | const gtsam::Pose3 & | deltaPose, |
| const Eigen::Matrix< double, 6, 1 > & | poseBetweenNoiseDensity, | ||
| double | lidarTimeKm1, | ||
| double | lidarTimeK, | ||
| double | rate, | ||
| const RobustNormEnum & | robustNormEnum, | ||
| const double | robustNormConstant ) |
Definition at line 418 of file GraphManager.cpp.
◆ addUnaryClassicFactor()
| void holistic_fusion::GraphManager::addUnaryClassicFactor | ( | const MEASUREMENT_TYPE & | unaryMeasurement, |
| const Eigen::Matrix< double, NOISE_DIM, 1 > & | unaryNoiseDensity, | ||
| double | measurementTime, | ||
| const FACTOR_ARGS &... | factorArgs ) |
◆ addUnaryHolisticFactor()
| void holistic_fusion::GraphManager::addUnaryHolisticFactor | ( | const std::shared_ptr< GMSF_EXPRESSION_TYPE > | gmsfUnaryExpressionPtr, |
| const bool | addToOnlineSmootherFlag = true ) |
◆ calculateNavStateAtGeneralKey()
|
staticprotected |
Definition at line 482 of file GraphManager.cpp.
◆ calculatePoseCovarianceAtKeyInWorldFrame()
|
staticprotected |
Definition at line 504 of file GraphManager.cpp.
◆ calculateStateAtGeneralKey()
| gtsam::NavState holistic_fusion::GraphManager::calculateStateAtGeneralKey | ( | bool & | computeSuccessfulFlag, |
| const gtsam::Key & | generalKey ) |
Definition at line 1250 of file GraphManager.cpp.
◆ extractBatchOptimizationResult_()
|
private |
Definition at line 1270 of file GraphManager.cpp.
◆ findGraphKeys_()
|
private |
Find graph keys for timestamps.
Definition at line 1380 of file GraphManager.cpp.
◆ getInitAccBiasReference()
|
inline |
Getters.
Definition at line 132 of file GraphManager.h.
◆ getInitGyrBiasReference()
|
inline |
Definition at line 133 of file GraphManager.h.
◆ getOptimizedGraphState()
|
inline |
Definition at line 136 of file GraphManager.h.
◆ getPropagatedStateKey()
|
inline |
Definition at line 137 of file GraphManager.h.
◆ getUnaryFactorGeneralKey()
| bool holistic_fusion::GraphManager::getUnaryFactorGeneralKey | ( | gtsam::Key & | returnedKey, |
| double & | returnedGraphTime, | ||
| const UnaryMeasurement & | unaryMeasurement ) |
Definition at line 380 of file GraphManager.cpp.
◆ hasReferenceFrameKeyframe()
| bool holistic_fusion::GraphManager::hasReferenceFrameKeyframe | ( | const std::string & | worldFrame, |
| const std::string & | fixedFrame ) |
Definition at line 374 of file GraphManager.cpp.
◆ initImuIntegrators()
| bool holistic_fusion::GraphManager::initImuIntegrators | ( | double | gravityValue | ) |
Position
Rotation
Earth rotation: angular velocity of the (gravity-aligned, z-up) world frame w.r.t. the inertial frame, expressed in the world frame. Setting it makes GTSAM (>= 4.3) use the exact rotating-frame model (Coriolis, centrifugal and Earth-rate terms). If left unset, the inertial model is used.
Bias
Definition at line 92 of file GraphManager.cpp.
◆ initPoseVelocityBiasGraph()
| bool holistic_fusion::GraphManager::initPoseVelocityBiasGraph | ( | double | timeStamp, |
| const gtsam::Pose3 & | T_W_I0, | ||
| const gtsam::Pose3 & | T_O_I0, | ||
| const gtsam::Vector3 & | imuAngularVelocity ) |
Prior factor noise
Timestamp mapping for incremental fixed lag smoother
Add prior factor to graph and optimize for the first time -------------—
Definition at line 131 of file GraphManager.cpp.
◆ logLatencyAndUpdateDuration()
| bool holistic_fusion::GraphManager::logLatencyAndUpdateDuration | ( | const std::string & | savePath, |
| const std::string & | timeString ) |
Definition at line 985 of file GraphManager.cpp.
◆ logRealTimeNavStates()
| bool holistic_fusion::GraphManager::logRealTimeNavStates | ( | const std::string & | savePath, |
| const std::string & | timeString ) |
Definition at line 879 of file GraphManager.cpp.
◆ logRealTimeReferenceFrameStates()
| bool holistic_fusion::GraphManager::logRealTimeReferenceFrameStates | ( | const std::string & | savePath, |
| const std::string & | timeString ) |
Definition at line 925 of file GraphManager.cpp.
◆ newPropagatedStateKey_()
|
inlineprivate |
Generate new key.
Definition at line 178 of file GraphManager.h.
◆ optimizeSlowBatchSmoother() [1/2]
| std::optional< BatchOptimizationResult > holistic_fusion::GraphManager::optimizeSlowBatchSmoother | ( | int | maxIterations, |
| const bool | computePoseCovarianceFlag ) |
Definition at line 871 of file GraphManager.cpp.
◆ optimizeSlowBatchSmoother() [2/2]
| bool holistic_fusion::GraphManager::optimizeSlowBatchSmoother | ( | int | maxIterations, |
| const std::string & | savePath, | ||
| const bool | saveCovarianceFlag ) |
Definition at line 862 of file GraphManager.cpp.
◆ runSlowBatchSmootherOptimization_()
|
private |
Definition at line 1256 of file GraphManager.cpp.
◆ saveOptimizedGraphToG2o()
|
static |
Definition at line 1243 of file GraphManager.cpp.
◆ saveOptimizedValuesToFile()
| void holistic_fusion::GraphManager::saveOptimizedValuesToFile | ( | const gtsam::Values & | optimizedValues, |
| const std::map< gtsam::Key, double > & | keyTimestampMap, | ||
| const std::string & | savePath, | ||
| const bool | saveCovarianceFlag ) |
Definition at line 1029 of file GraphManager.cpp.
◆ setInitialWorldFrameToFixedFrameTransform()
| bool holistic_fusion::GraphManager::setInitialWorldFrameToFixedFrameTransform | ( | const Eigen::Isometry3d & | T_W_F, |
| const std::string & | fixedFrame ) |
Definition at line 364 of file GraphManager.cpp.
◆ updateGraph()
| void holistic_fusion::GraphManager::updateGraph | ( | ) |
Definition at line 534 of file GraphManager.cpp.
◆ updateImuIntegrators_()
|
private |
Update IMU integrators.
Definition at line 1304 of file GraphManager.cpp.
◆ writeKeyToKeyTimeStampMap_()
|
inlineprivate |
Associate timestamp to each 'value key', e.g. for graph key 0, value keys (x0,v0,b0) need to be associated.
◆ writeValueKeysToKeyTimeStampMap_()
|
private |
Definition at line 1413 of file GraphManager.cpp.
Member Data Documentation
◆ batchFactorGraphBufferPtr_
|
private |
Definition at line 216 of file GraphManager.h.
◆ batchGraphKeysTimestampsMapBufferPtr_
|
private |
Definition at line 222 of file GraphManager.h.
◆ batchGraphValuesBufferPtr_
|
private |
Definition at line 219 of file GraphManager.h.
◆ batchOptimizerPtr_
|
private |
Definition at line 213 of file GraphManager.h.
◆ fileLogger_
|
private |
Definition at line 195 of file GraphManager.h.
◆ graphConfigPtr_
|
private |
Config.
Definition at line 234 of file GraphManager.h.
◆ gtsamDynamicExpressionKeys_
|
private |
Definition at line 192 of file GraphManager.h.
◆ imuBiasPriorPtr_
|
private |
Definition at line 199 of file GraphManager.h.
◆ imuBufferPreintegratorPtr_
|
private |
Buffer Preintegrator.
Definition at line 228 of file GraphManager.h.
◆ imuFrame_
|
private |
Definition at line 190 of file GraphManager.h.
◆ imuParamsPtr_
|
private |
Definition at line 198 of file GraphManager.h.
◆ imuStepPreintegratorPtr_
|
private |
Step Preintegrator.
Definition at line 226 of file GraphManager.h.
◆ lastImuVector_
|
private |
IMU Buffer.
Definition at line 231 of file GraphManager.h.
◆ lastOptimizedStateTime_
|
private |
Definition at line 208 of file GraphManager.h.
◆ latencyContainer_
|
private |
Definition at line 246 of file GraphManager.h.
◆ latencyEndTime_
|
private |
Definition at line 244 of file GraphManager.h.
◆ latencyStartTime_
|
private |
Definition at line 243 of file GraphManager.h.
◆ latestGraphStateKeyAngularVelocity_
|
private |
Definition at line 209 of file GraphManager.h.
◆ latestGraphStateKeyTime_
|
private |
Definition at line 207 of file GraphManager.h.
◆ O_imuPropagatedState_
|
private |
Definition at line 203 of file GraphManager.h.
◆ operateOnGraphDataMutex_
|
private |
Mutex.
Definition at line 255 of file GraphManager.h.
◆ optimizationRunningMutex_
|
private |
Definition at line 256 of file GraphManager.h.
◆ optimizedGraphState_
|
private |
Definition at line 200 of file GraphManager.h.
◆ propagatedImuSampleTime_
|
private |
Definition at line 206 of file GraphManager.h.
◆ propagatedStateKey_
|
private |
Definition at line 205 of file GraphManager.h.
◆ realTimeOdomPoseContainer_
|
private |
Definition at line 238 of file GraphManager.h.
◆ realTimeReferenceFrameContainer_
|
private |
Definition at line 240 of file GraphManager.h.
◆ realTimeReferenceFrameNamePairs_
|
private |
Definition at line 241 of file GraphManager.h.
◆ realTimeWorldPoseContainer_
|
private |
Definition at line 237 of file GraphManager.h.
◆ rtFactorGraphBufferPtr_
|
private |
Data buffer.
Definition at line 215 of file GraphManager.h.
◆ rtGraphKeysTimestampsMapBufferPtr_
|
private |
Definition at line 221 of file GraphManager.h.
◆ rtGraphValuesBufferPtr_
|
private |
Definition at line 218 of file GraphManager.h.
◆ rtOptimizerPtr_
|
private |
Definition at line 212 of file GraphManager.h.
◆ T_W_O_
|
private |
Definition at line 204 of file GraphManager.h.
◆ timeToKeyBufferPtr_
|
private |
Definition at line 187 of file GraphManager.h.
◆ updateDurationContainer_
|
private |
Definition at line 251 of file GraphManager.h.
◆ updateDurationEndTime_
|
private |
Definition at line 249 of file GraphManager.h.
◆ updateDurationStartTime_
|
private |
Definition at line 248 of file GraphManager.h.
◆ W_imuPropagatedState_
|
private |
Propagated state (at IMU frequency).
Definition at line 202 of file GraphManager.h.
◆ worldFrame_
|
private |
Definition at line 191 of file GraphManager.h.
The documentation for this class was generated from the following files:
- holistic_fusion/include/holistic_fusion/core/GraphManager.h
- holistic_fusion/src/lib/GraphManager.cpp
